Mechanical systems
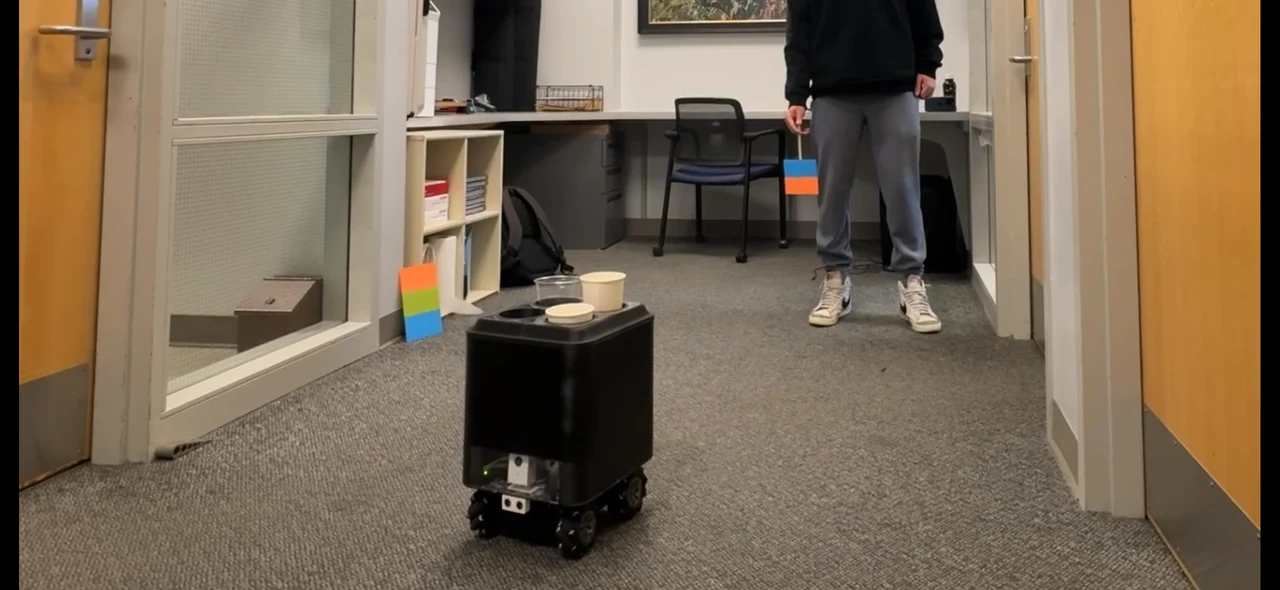
Autonomous Cafe Delivery Robot
I programmed the navigation, calibrated the motors, and designed adjustable cupholders for a four-cup delivery robot.
Role: I led programming, electronics integration, wiring, and much of the mechanical design, fabrication, and testing.