Autonomous Cafe Delivery Robot
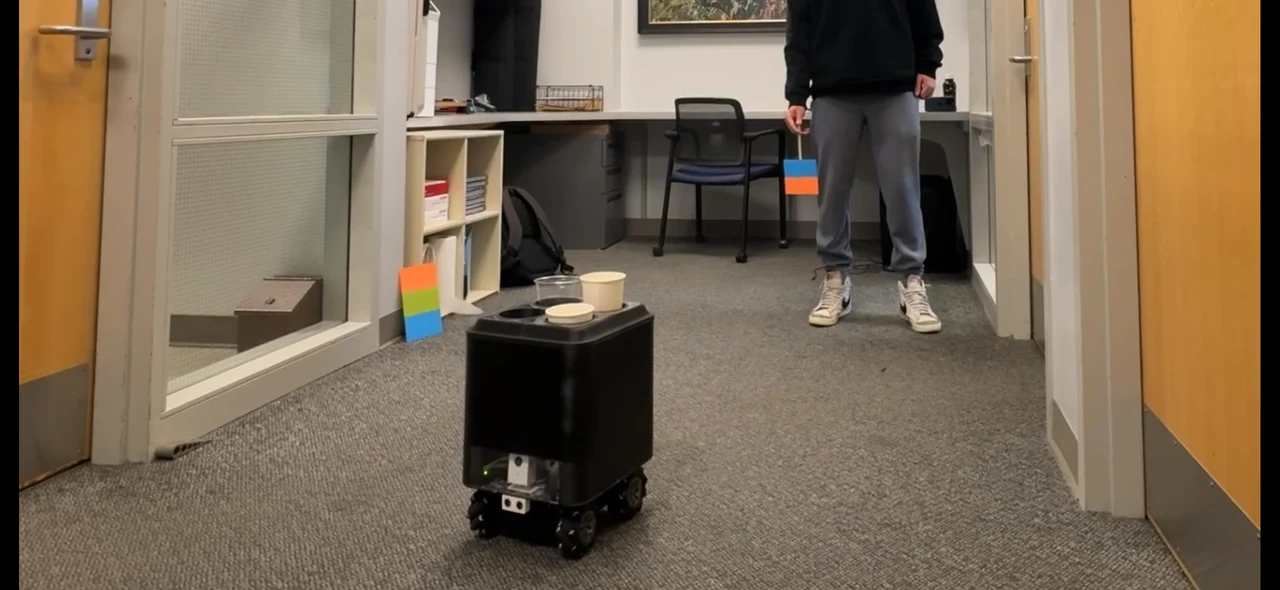
I programmed the navigation, calibrated the motors, and designed adjustable cupholders for a four-cup delivery robot.
Best in Automation · CU Robotics Club · Spring 2026
Inside the project: wheel-speed calibration, visual targets, and a modular cupholder.
Read the case study